Eight worlds. Eight ways to act.
Explore the task scenes, from subsea intervention and industrial work to satellite servicing in orbit.
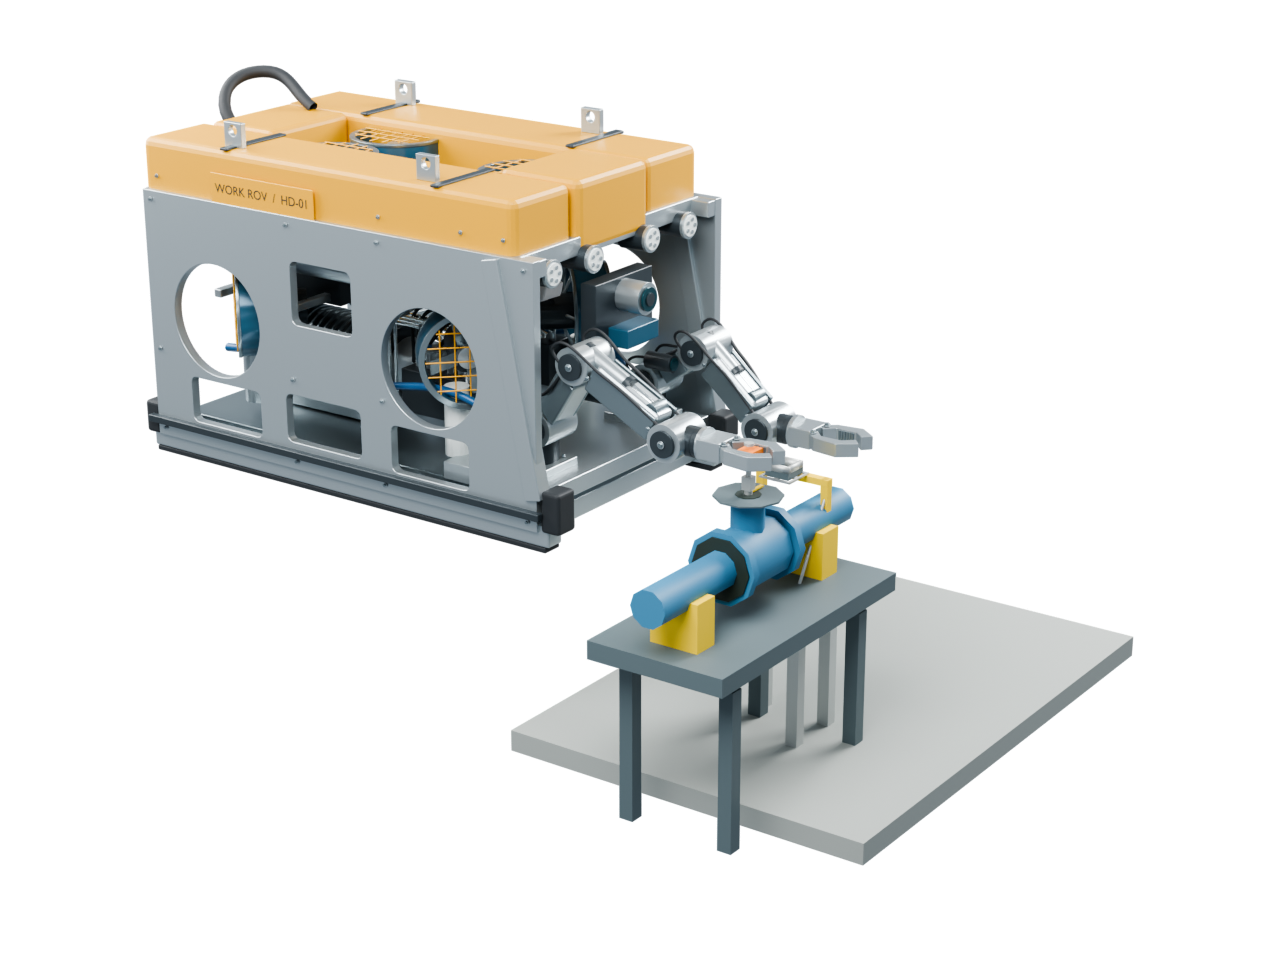
Subsea valve operation
The original industrial ROV and square-drive tool approach the subsea valve.
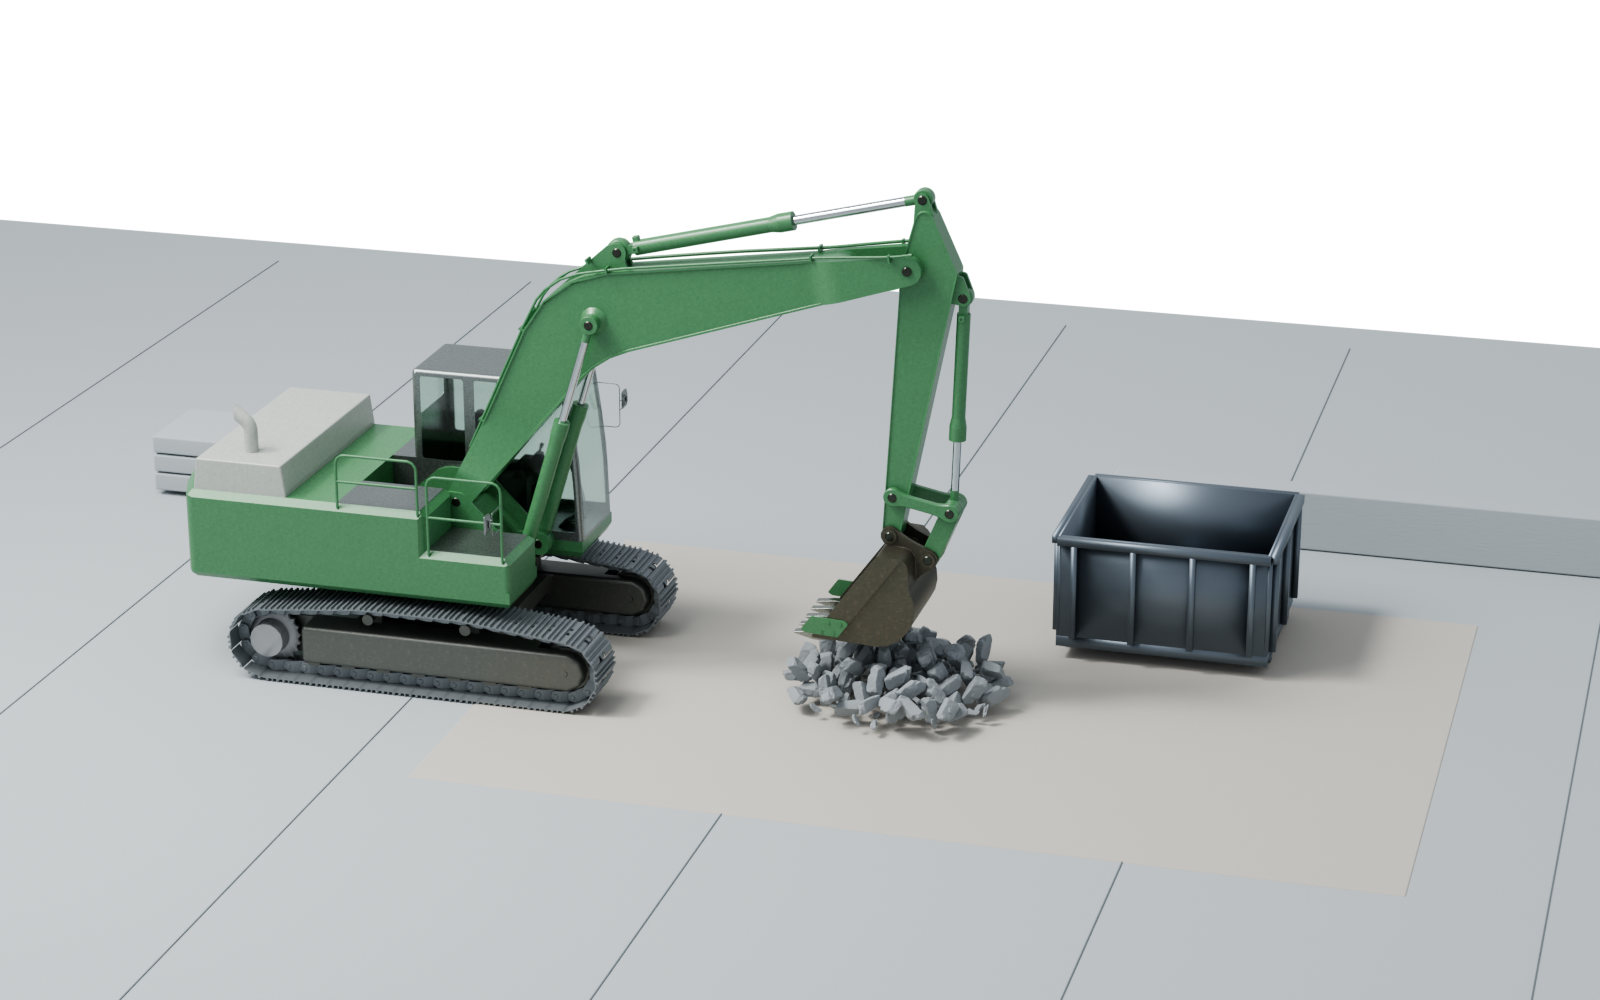
Coarse aggregate loading
The green CET machine works with the original coarse stone pile and open steel bin.
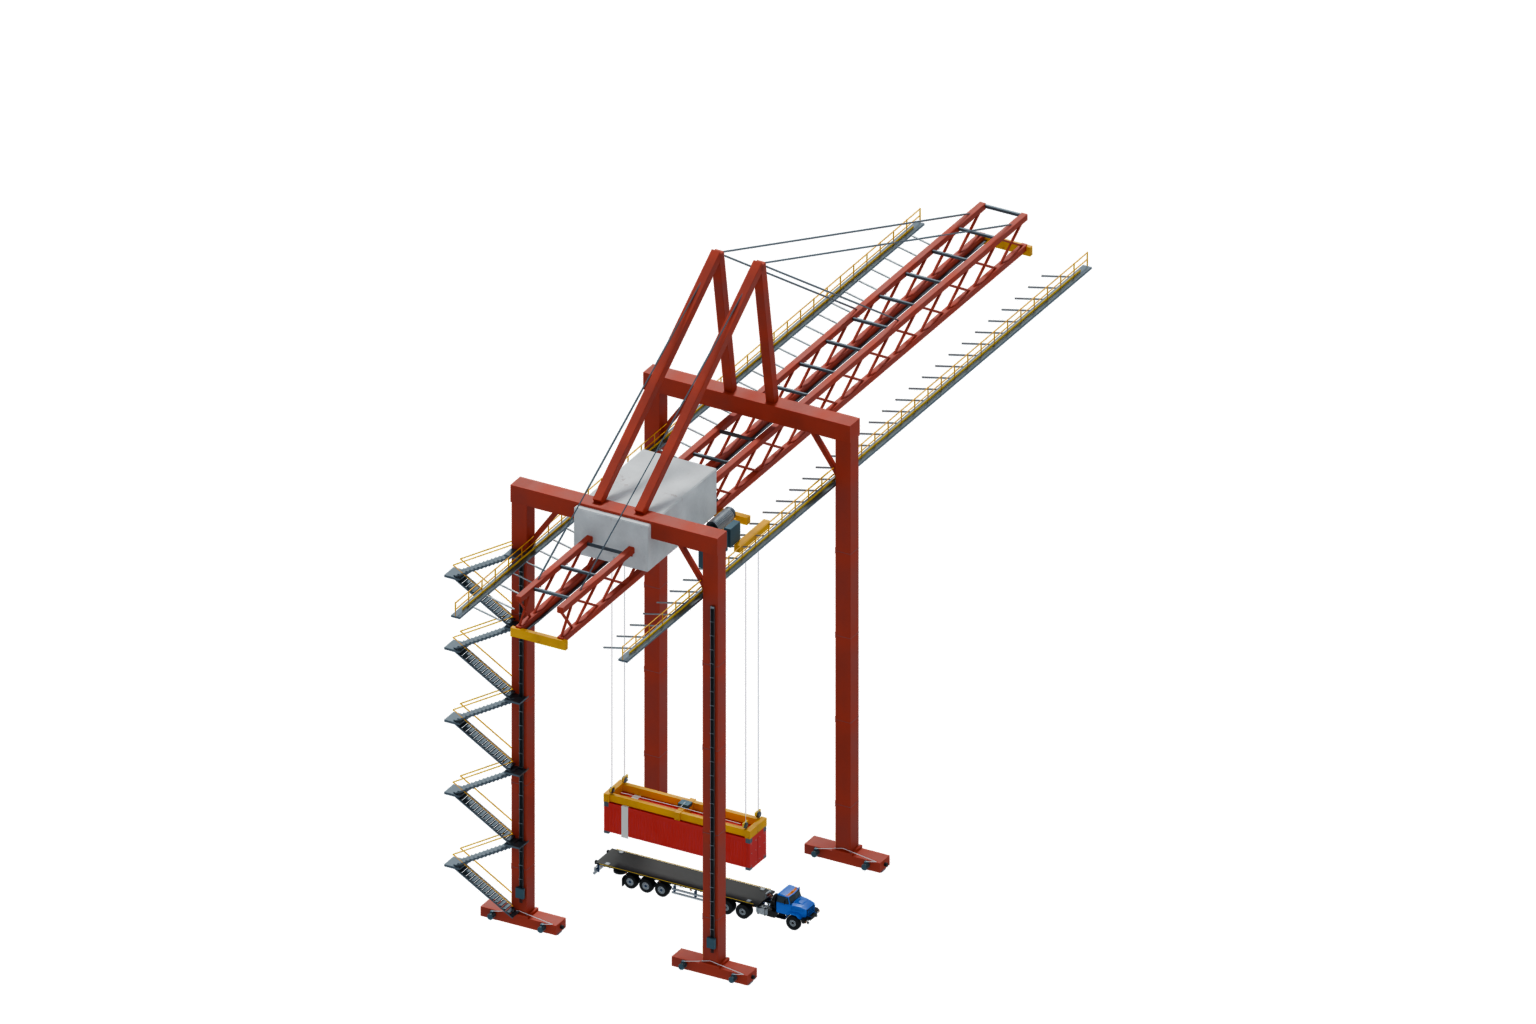
Container loading onto a truck
The E2204 STS crane lowers the red white-striped container toward the blue-cab truck in task E2204-T1001.
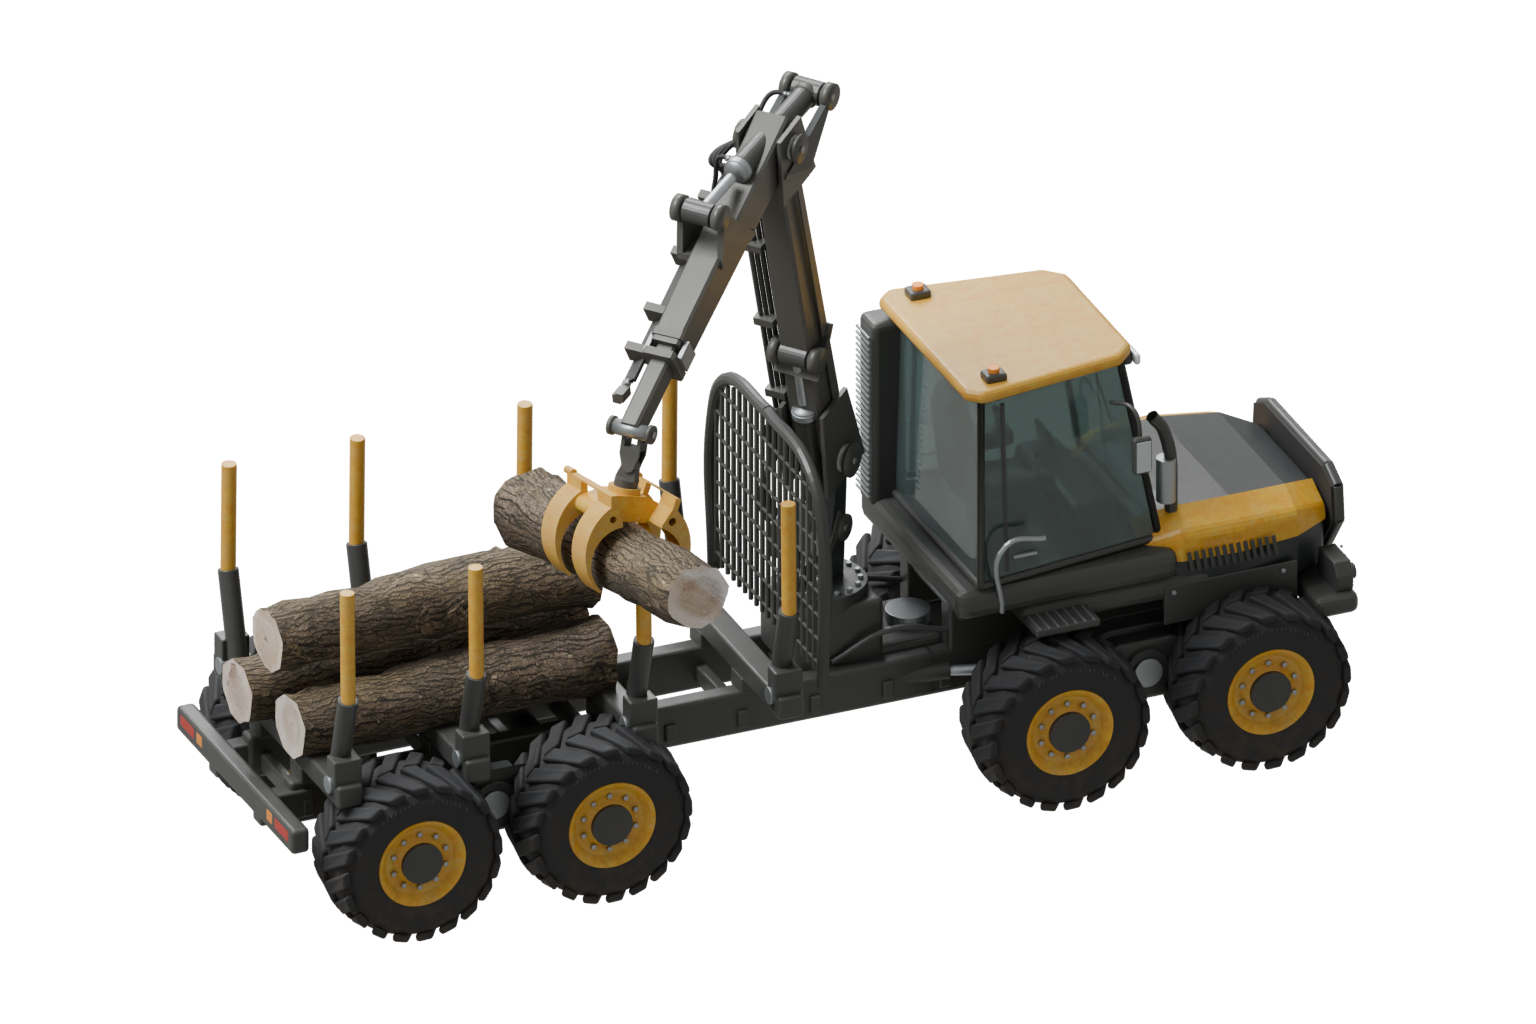
Forestry log collection
The original forestry forwarder holds one of four native logs, with three logs on its bunk.
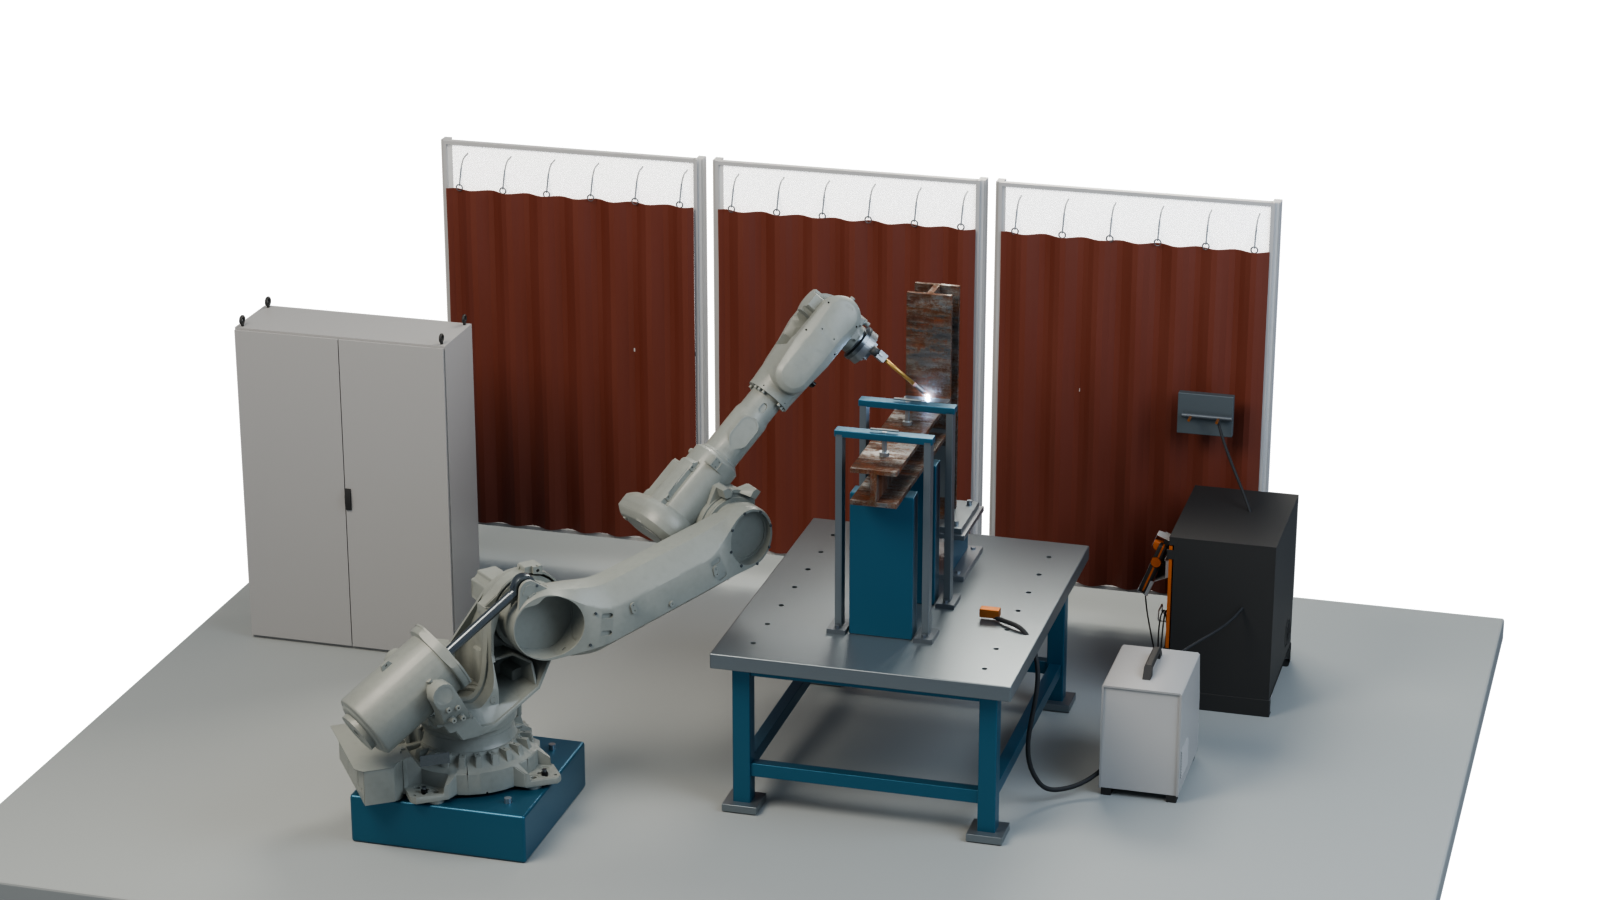
Robotic welding
The original ABB robot and welding torch follow the native beam-column seam in a recorded visual replay.
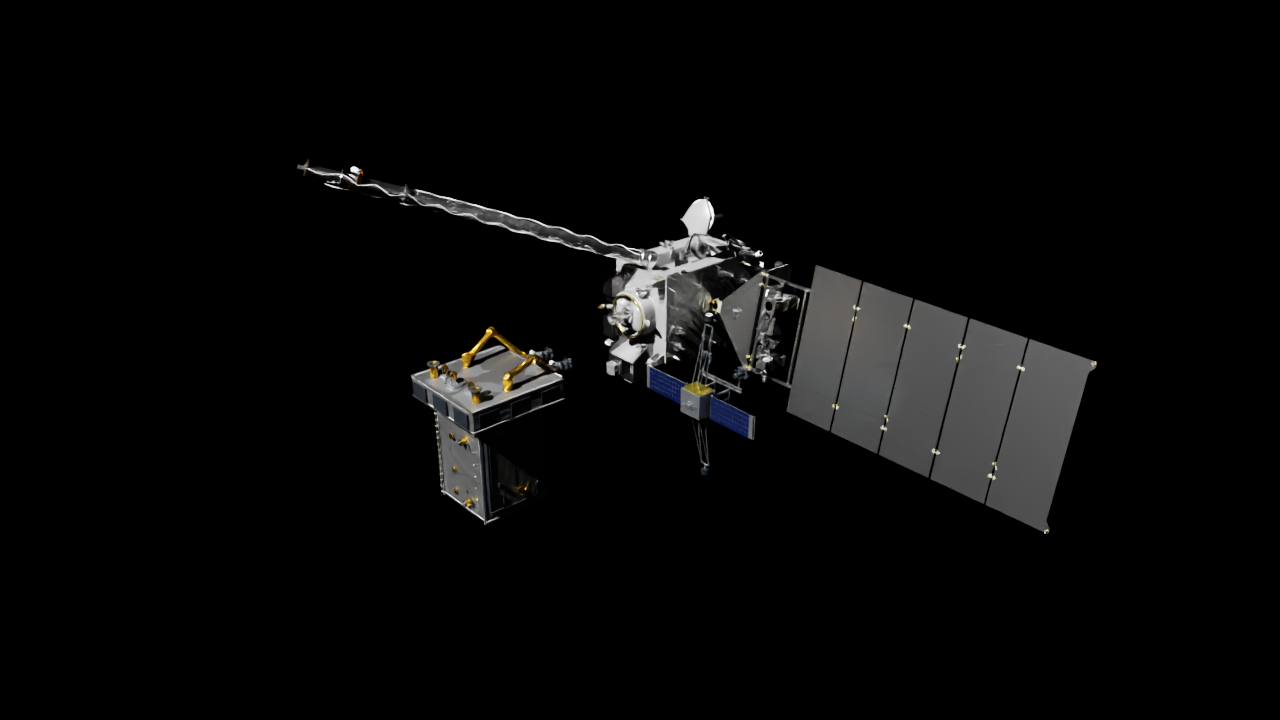
Satellite life-extension pod installation
The original MRV installs a mission extension pod on the client satellite.
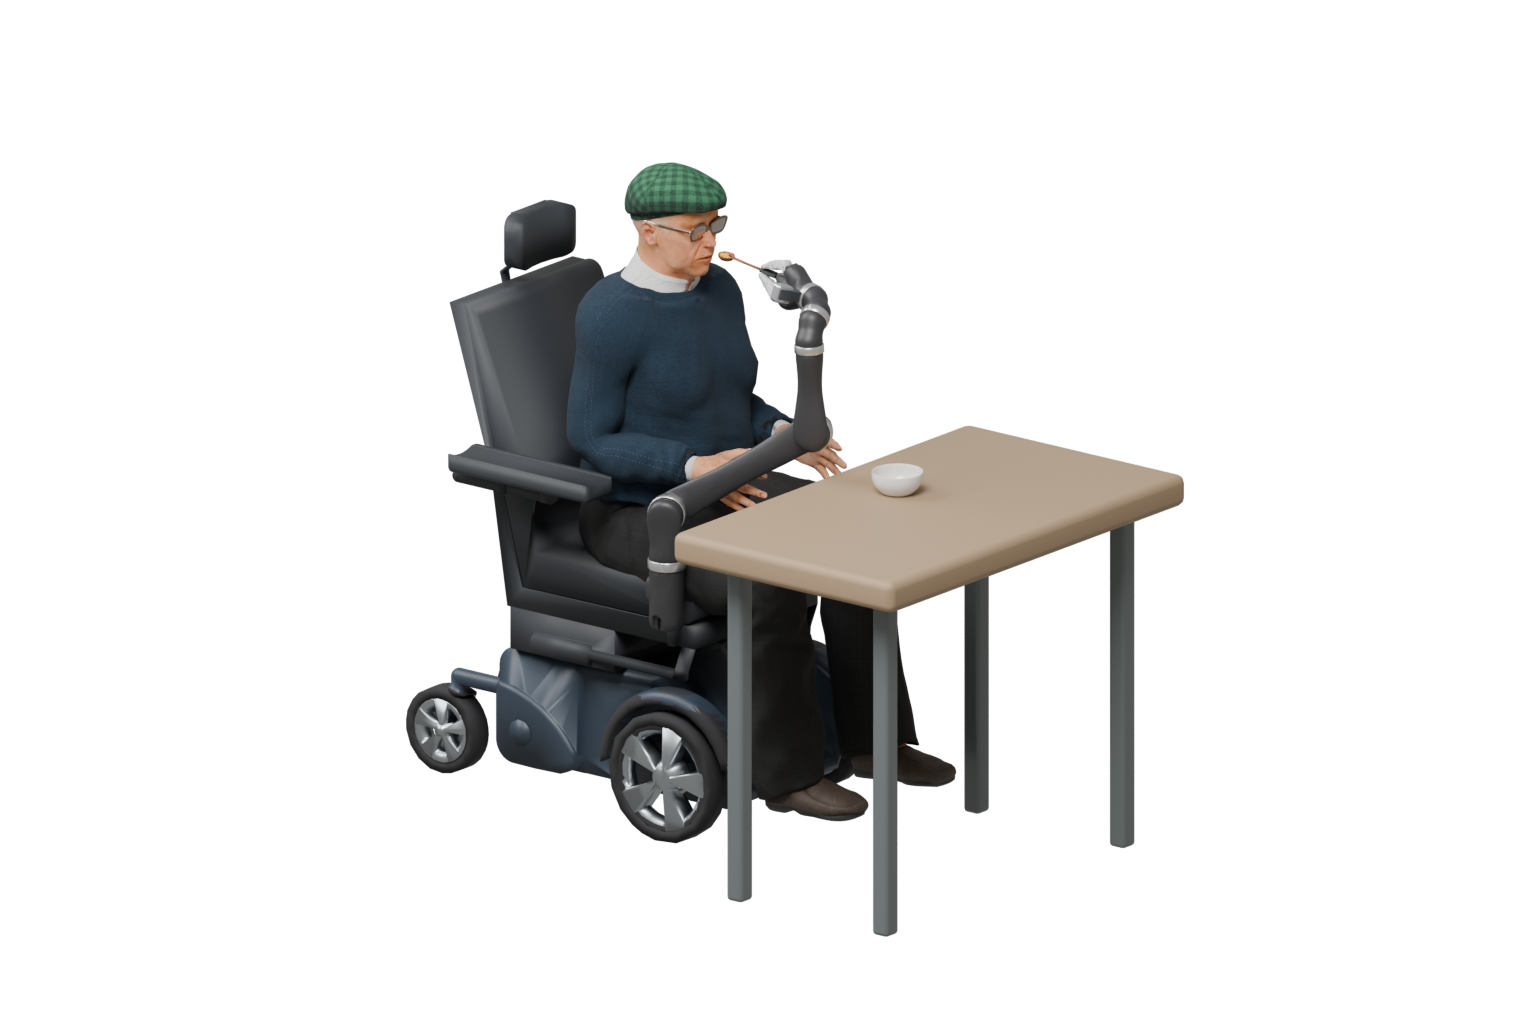
Wheelchair-assisted feeding
The original wheelchair-mounted black JACO2 arm presents a wooden spoon with corn to Ernest.
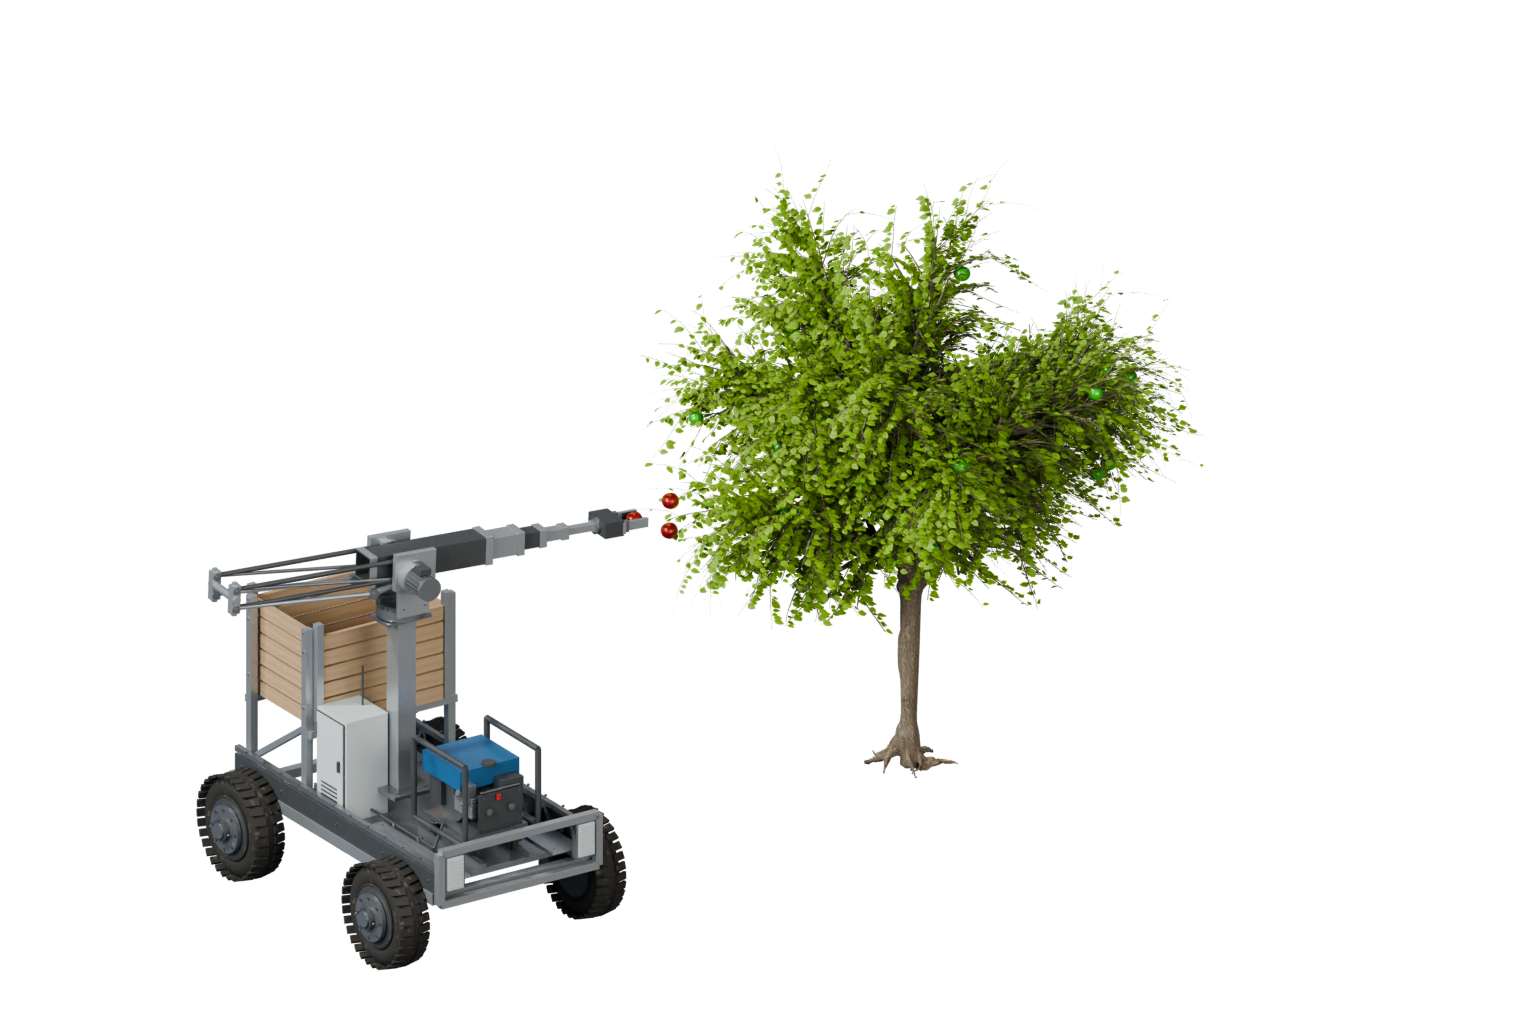
Apple harvesting
The original EVE mobile harvester approaches a nearby apple tree with its native telescoping mechanism and parallel-jaw gripper.
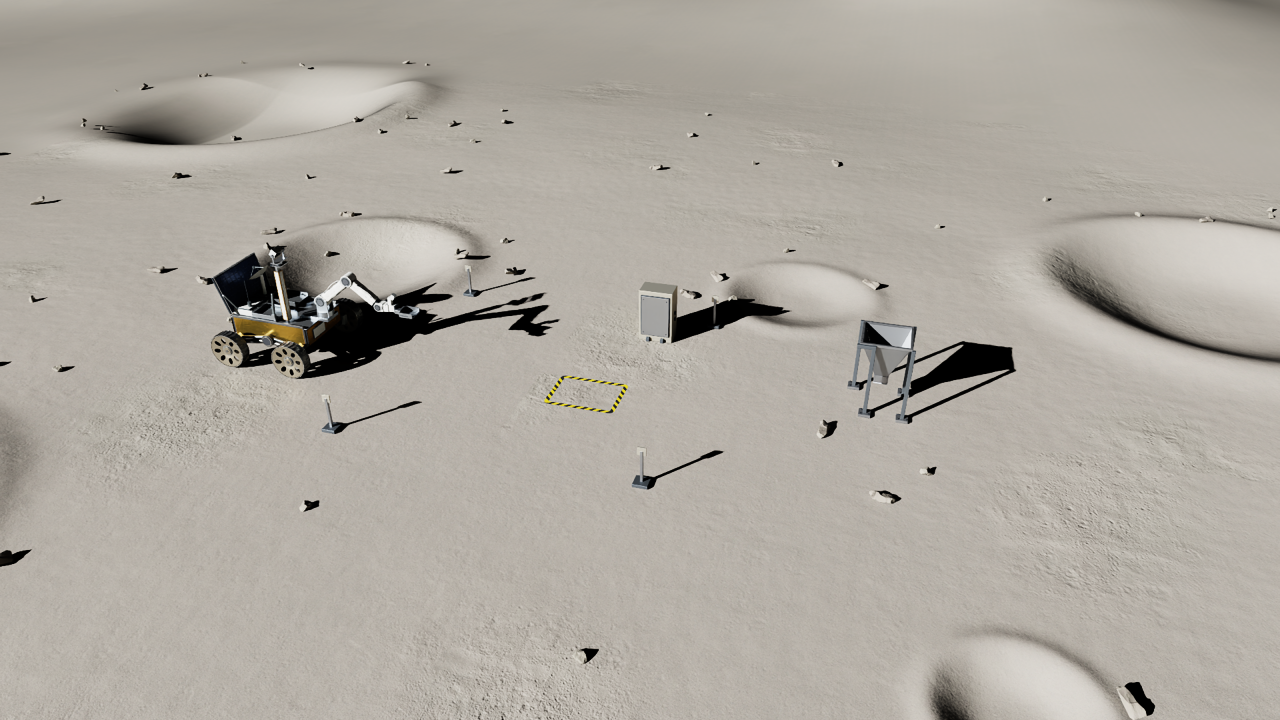
Lunar regolith collection
The E5101 lunar excavator collects regolith and transfers it to the receiving hopper.